eBook[PDF]

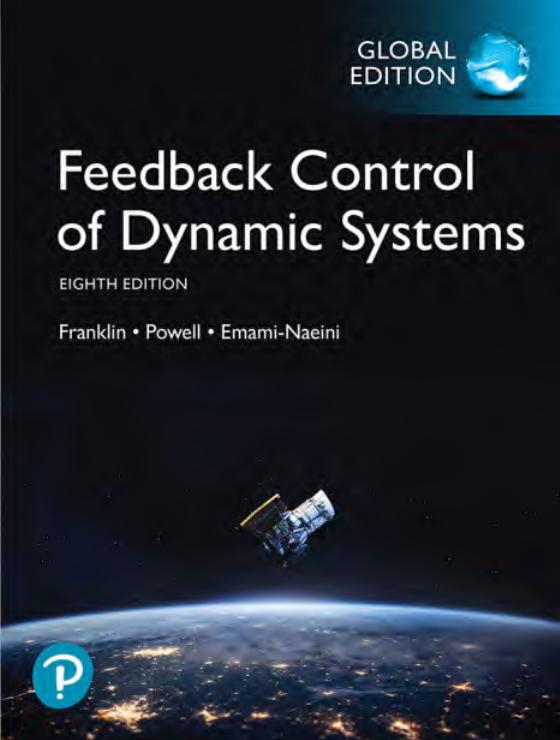
Feedback Control of Dynamic Systems 8th Global Edition By Gene Franklin, David Powell, Abbas Emami-Naeini

$30.00
✓ Secure checkout
✓ Instant digital download
✓ PDF document

Document details

Pages
1,046
File size
5.75 MB
Format
Digital PDF
Category
eBook[PDF]
About this ebook
The 8th Global Edition of Feedback Control of Dynamic Systems by Gene Franklin, David Powell, and Abbas Emami-Naeini structures its material around core control engineering tenets: stability, tracking, robustness, and system design. [1, 2, 3]
The textbook is divided into 10 comprehensive chapters alongside supplemental reference material and appendices. [1]
Core Table of Contents & Topics Covered
  • Chapter 1: An Overview and Brief History of Feedback Control
    • Essential concepts of open-loop vs. closed-loop control.
    • Components of a feedback system (sensors, actuators, plant, controller).
    • Historical developments from early industrial mechanics to aerospace applications. [1, 2, 3, 4]
  • Chapter 2: Dynamic Models
    • Differential equations for physical systems.
    • Modeling of mechanical, electrical, electro-mechanical, fluid, and thermodynamic devices.
    • State-variable formulations and introduction to block diagrams. [1, 2, 3, 4]
  • Chapter 3: Dynamic Response
    • Review of Laplace transforms and system transfer functions.
    • Correlation between system pole/zero locations and transient responses.
    • Analysis of first-order and second-order system responses. [1, 2, 3]
  • Chapter 4: A First Analysis of Feedback
    • The structural advantages of feedback control (reduction of sensitivity to parameter variations).
    • Control of steady-state error and system tracking.
    • Introduction to PID (Proportional-Integral-Derivative) controllers. [1, 2, 3]
  • Chapter 5: The Root-Locus Design Method
    • Guidelines and rules for plotting root loci.
    • Control design using root-locus techniques.
    • Lead and lag compensation networks. [1, 2]
  • Chapter 6: The Frequency-Response Design Method
    • Bode plots, Nyquist stability criteria, and Nichols charts.
    • Gain margin and phase margin calculations.
    • System specifications in terms of frequency response metrics. [1, 2]
  • Chapter 7: State-Space Design
    • Controllability and observability metrics.
    • Pole placement techniques for state feedback.
    • Design of state estimators (observers). [1]
  • Chapter 8: Digital Control
    • Sampling of continuous signals and the Z-transform.
    • Analysis of discrete-time systems.
    • Digital implementation of continuous controllers and direct digital design. [1, 2]
  • Chapter 9: Nonlinear Systems
    • Introduction to common nonlinearities (saturation, dead-zone, backlash).
    • Linearization techniques for complex dynamic models.
    • Phase-plane analysis and Lyapunov stability analysis. [1, 2, 3]
  • Chapter 10: Control Systems Design: Principles and Case Studies
    • Real-world application problems spanning multiple fields.
    • Integration of dynamic modeling, frequency-response, and state-space methods into cohesive final designs. [1, 2]
Appendices and Auxiliary Content
  • Appendix A: Laplace Transforms
  • Appendix B: Solutions to Review Problems
  • Appendix C: MATLAB Commands (heavily integrated for scripting and Simulink usage throughout the text). [1, 2]

File included

PDF
tmpphpHeGXN8 5.75 MB

Topics

An Overview and Brief History of Feedback Control Analysis of discrete-time systems Components of a feedback system (sensors actuators plant controller) Control design using root-locus techniques Control of steady-state error and system tracking Control Systems Design: Principles and Case Studies Correlation between system pole/zero locations and transient responses Design of state estimators (observers) Digital Control Sampling of continuous signals and the Z-transform Digital implementation of continuous controllers and direct digital design Dynamic Models Differential equations for physical systems Dynamic Response Review of Laplace transforms and system transfer functions Essential concepts of open-loop vs. closed-loop control. Gain margin and phase margin calculations Integration of dynamic modeling frequency-response and state-space methods into cohesive final designs Introduction to common nonlinearities (saturation dead-zone backlash) Introduction to PID (Proportional-Integral-Derivative) controllers ISBN-13: 978-0134685717 ISBN-13: 978-1292274522 ISBN-13: 978-1292274546 ISBN-13: 978-9353949525 Lead and lag compensation networks MATLAB Commands (heavily integrated for scripting and Simulink usage Modeling of mechanical electrical electro-mechanical fluid and thermodynamic devices Nonlinear Systems Phase-plane analysis and Lyapunov stability analysis Real-world application problems spanning multiple fields State-Space Design Controllability and observability metrics State-variable formulations and introduction to block diagrams System specifications in terms of frequency response metrics The Frequency-Response Design Method Bode plots Nyquist stability criteria and Nichols charts The Root-Locus Design Method Guidelines and rules for plotting root loci The structural advantages of feedback control (reduction of sensitivity to parameter variations).